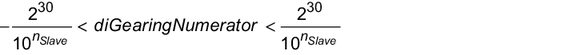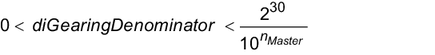Synchronous operation (gearing)
Parameter designation | Description |
|---|---|
Synchronous operation | |
Master source |
|
Index: 50009.5 | |
IEC name: – | |
Master axis name INFORMATION: Visible when master source is "Configured axis". | Selects the master axis |
Index: 50009.1 | |
IEC name: – | |
Name of EncoderInterface INFORMATION: Visible when master source is "EncoderInterface". | Selection of the EncoderInterface |
Index: 50009.11 | |
IEC name: – | |
Settings of the master source INFORMATION: Visible when master source is "User program". | |
Modulo minimum | Modulo minimum Default value: 0 |
Index: 50009.4 | |
IEC name: ProfileGeneration.Gearing.Config.lrMasterModuloMin | |
Modulo maximum | Modulo maximum Default value: 0 |
Index: 50009.3 | |
IEC name: ProfileGeneration.Gearing.Config.lrMasterModuloMax | |
Number of decimal places | Number of decimal places Default value: 4 |
Index: 50009.28 | |
IEC name: ProfileGeneration.Gearing.Config.uiMasterResolution | |
Time factor for speed | Time factor for speed Default value: 1/min |
Index: 50009.29 | |
IEC name: ProfileGeneration.Gearing.Config.stTimeBaseFactor.eVelocity | |
Time factor for acceleration | Time factor for acceleration Default value: 1/min^2 |
Index: 50009.30 | |
IEC name: ProfileGeneration.Gearing.Config.stTimeBaseFactor.eAcceleration | |
Master/slave gear ratio | |
Numerator | Numerator value (diGearingNumerator) of the gear ratio between master and slave in user units of the slave axis. The following limit applies:
Default value: 1 |
Index: 50009.6 | |
IEC name: ProfileGeneration.Gearing.In.diGearingNumerator | |
Denominator | Denominator value (diGearingDenominator) of the gear ratio between master and slave in user units of the master axis. The following limit applies:
Default value: 1 |
Index: 50009.7 | |
IEC name: ProfileGeneration.Gearing.In.diGearingDenominator | |
Synchronizing | |
Synchronization behavior |
|
Index: 50009.13 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Start.eStartMode | |
Synchronization transition |
|
Index: 50009.22 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Start.eStartTransition | |
Synchronization distance INFORMATION: Visible when synchronization transition is "Path-based". | Synchronization distance (master) Default value: 0 |
Index: 50009.8 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Start.lrGearInDistance | |
Synchronization time INFORMATION: Visible when synchronization transition is "Time-based". | Synchronization time (in s) Default value: 0 |
Index: 50009.20 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Start.lrGearInTime | |
Synchronization offset INFORMATION: Visible when coupling with reference position and master. | Offset (master) Default value: 0 |
Index: 50009.9 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Start.lrGearInOffset | |
Reference position during synchronization INFORMATION: Visible when coupling with reference position and master. | Reference position during synchronization Default value: 0 |
Index: 50009.10 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Start.lrGearInReferencePosition | |
Desynchronizing | |
Desynchronization behavior |
|
Index: 50009.14 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Stop.eStopMode | |
Desynchronization transition |
|
Index: 50009.23 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Stop.eStopTransition | |
Desynchronization distance INFORMATION: Visible when desynchronization transition is "Path-based". | Desynchronization distance (master) Default value: 0 |
Index: 50009.11 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Stop.lrGearOutDistance | |
Desynchronization time INFORMATION: Visible when desynchronization transition is "Time-based". | Desynchronization time (in s) Default value: 0 |
Index: 50009.21 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Stop.lrGearOutTime | |
Stop position after desynchronization INFORMATION: Visible when uncoupling with stop position of the external master. | Stop position after desynchronization Default value: 0 |
Index: 50009.12 | |
IEC name: ProfileGeneration.Gearing.CONFIG.Stop.lrGearOutStopPosition | |
Y offset correction | |
Mode |
|
Index: 50009.34 | |
IEC name: ProfileGeneration.Gearing.YOffsetCorrection.eOffsetCorrectionMode | |
Transition | Type of travel profile:
|
Index: 50009.35 | |
IEC name: ProfileGeneration.Gearing.YOffsetCorrection.eTransitionType | |
Master distance INFORMATION: Visible when transition is "Path-based". | Distance of the master axis within which a master-based offset correction is performed. Default value: 0 |
Index: 50009.36 | |
IEC name: ProfileGeneration.Gearing.YOffsetCorrection.lrMasterDistance | |