Configuring a MOVISUITE® project
The following figure shows the MOVISUITE® project underlying the application example. To implement the top drive, the software modules MOVIKIT® StackerCrane effiDRIVE, MOVIKIT® StackerCrane MultiAxisController and MOVIKIT® StackerCrane MultiMotion are used.
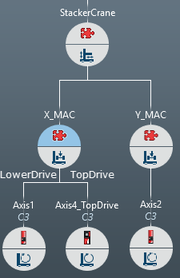

The "X_MAC" axis maps the X direction of the application, in which the lower drive ("LowerDrive") and top drive ("TopDrive") are implemented by means of a MOVIKIT® MultiAxisController. If multiple drives are used for the lower drive, they have to be cascaded by means of the MOVIKIT® MultiAxisController Torque and the MOVIKIT® MultiAxisController addon Cascading.
